Drill bits
Independent, reversible rotation
Lunar & Martian surface systems
Excavare X1 is a compact robotic excavation platform designed to drill, analyse and prepare extraterrestrial terrain before crews arrive.
01 / THE PLATFORM
Built for the Moon and Mars, X1 combines excavation, mobility and onboard analysis in one compact machine.
Its biological inspiration and proven rover mechanics turn difficult terrain into workable ground.
Independent, reversible rotation
Low-profile continuous mobility
Compact mission platform
02 / INTERACTIVE X1 EXPLORER
Choose a marked component on X1. Every feature is connected to a real mission task.
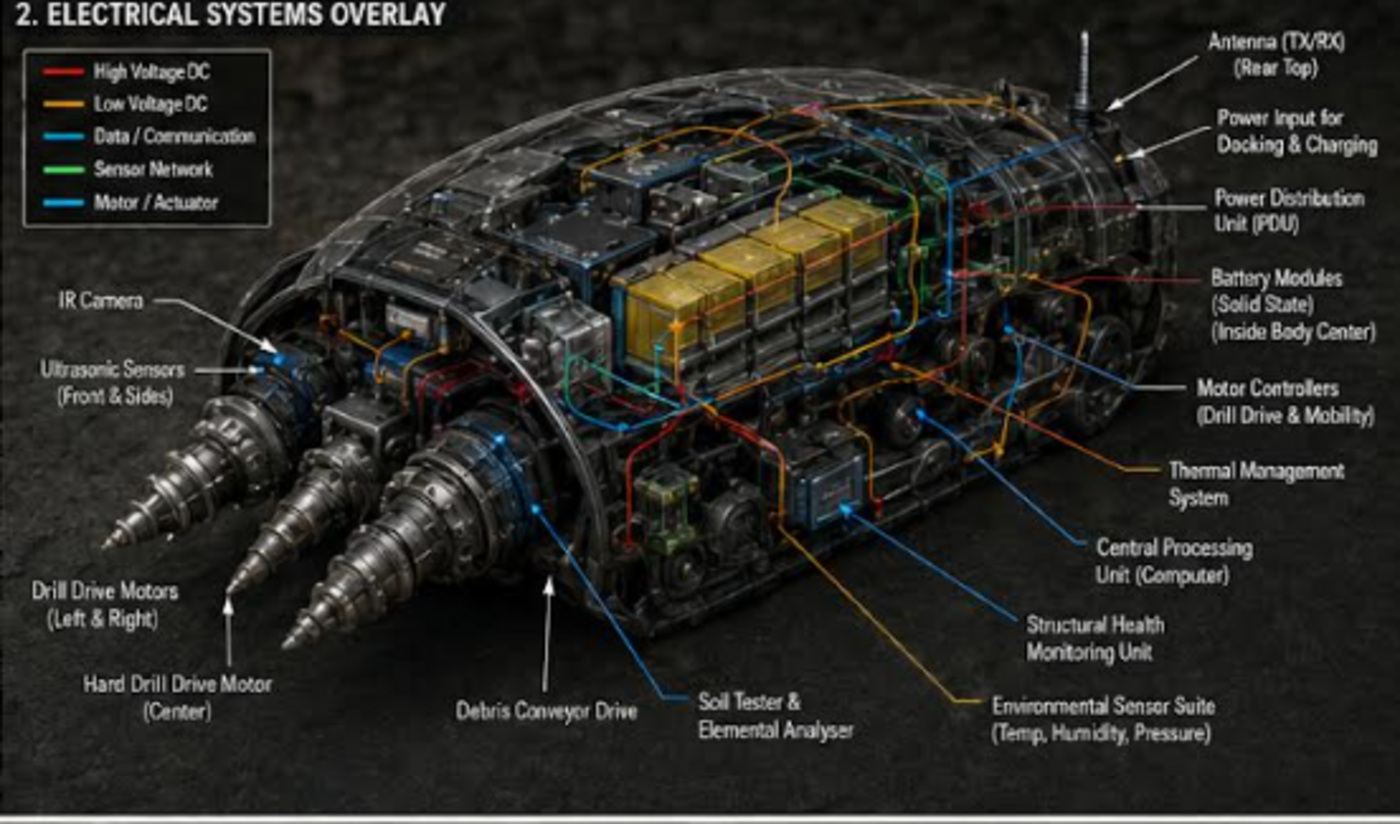
Click a numbered point to inspect the system.
03 / DRILL CONTROL
A simplified operator view demonstrates how X1 changes drill direction without turning the rover.
04 / CORE TECHNOLOGY
Every system has one job: keep X1 moving, drilling and learning with minimal human support.
Three articulated drill bits move vertically and rotate in either direction to break compacted regolith and collect material.
Twin continuous tracks spread the load and keep the body low while travelling through loose regolith.
LiDAR, infrared, soil sensors and a spectrometer work together to map, inspect and analyse each target area.
Rechargeable batteries support field operations, with automatic return to a parent rover or charging station.
05 / MISSION MODE
Prepare landing zones, cut utility trenches and excavate early foundation areas before crews arrive.
06 / OPERATING CYCLE
Select a stage to follow one complete field cycle.
Map a safe route to the selected work zone.
07 / MISSION VALUE
Designed for agencies, aerospace companies and research teams developing long-duration surface missions.
08 / ADVANCED EXPERIENCES
Five browser-based tools turn X1 from a presentation into an engineering experience.
Mission economics, X1 configuration, development roadmap, ISRU processing, a digital twin and failure-recovery controls—inside one technical operations suite.
Open systems suite ↗Rotate and explode the rover, inspect systems and test drill performance against simulated regolith.
Open engineering lab ↗02 / TERRAINSelect Moon or Mars terrain, draw a route and estimate slopes, trench volume, field time and energy.
Plan a route ↗03 / AUTONOMYPlan paths, coordinate an X1 swarm, test signal delay and model survival through the lunar cycle.
Deploy onboard AI ↗04 / WEBXRPlace the rover on a real floor with supported mobile AR, with a full 3D fallback everywhere else.
Enter AR viewer ↗09 / LEADERSHIP
A focused founding team combining leadership, operations, finance, marketing and science.
Strategy & vision
Technical operations
Finance & planning
Market & communication
Science & research
10 / CONTACT
Share a project, partnership idea or prototype demonstration request. The form creates a ready-to-send inquiry file without uploading your details.